Note
Go to the end to download the full example code.
Clumps (Rigid Bodies)#
A clump is a rigid body made of several spheres that move together.
Every sphere in the same clump shares its center-of-mass position
(pos_c), orientation (q), velocity (vel), angular velocity
(ang_vel), mass, and inertia. The remaining fields are stored
per-sphere: the body-frame offset (pos_p), the radius (rad),
the volume (volume), and the ID fields (mat_id, species_id,
bond_id, clump_id) — see the table below.
This guide covers:
The data model: which fields are shared and which are per-sphere.
Creating clumps manually and with
add_clump().Computing clump mass, inertia, and center of mass with
compute_clump_properties().How colliders, force aggregation, and integrators handle clumps.
Practical tips and common pitfalls.
The Clump Data Model#
Each particle slot in the state stores its own copy of the shared
fields. clump_id encodes clump membership: every slot with the same
clump_id belongs to the same rigid body.
Field |
Shared by clump |
Per-sphere |
|---|---|---|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
|
|
✓ |
Note
The state stores volume per sphere: create() defaults it to each
sphere’s own hypersphere volume, while
add_clump() broadcasts a provided clump
volume to every member sphere. Packing-fraction utilities read one
value per clump (via a segment max).
The actual position of each sphere in the lab frame is a computed property:
For a lone sphere pos_p = 0, so pos == pos_c.
import jax.numpy as jnp

import numpy as np

import jaxdem as jdem
Creating a Clump Manually#
The simplest way is to create individual spheres and assign the same
clump_id to those that form a rigid body. We also set their shared
pos_c (center of mass) and per-sphere pos_p (offset from the
center of mass in the body frame).
# Two spheres forming a dumbbell clump, plus one free sphere.
pos_c = jnp.array(
    [
        [2.0, 0.0],  # sphere 0 — dumbbell COM
        [2.0, 0.0],  # sphere 1 — same COM
        [6.0, 0.0],  # sphere 2 — free sphere
    ]
)
pos_p = jnp.array(
    [
        [-0.5, 0.0],  # sphere 0 is 0.5 to the left of COM
        [0.5, 0.0],  # sphere 1 is 0.5 to the right of COM
        [0.0, 0.0],  # sphere 2 — lone sphere, no offset
    ]
)
clump_id = jnp.array([0, 0, 1])  # 0,0 → same clump, 1 → separate clump

state = jdem.State.create(
    pos=pos_c,
    pos_p=pos_p,
    rad=jnp.array([0.6, 0.6, 1.0]),
    clump_id=clump_id,
)
print("clump_id:", state.clump_id)
print("pos_c   :", state.pos_c)
print("pos_p   :", state.pos_p)
print("pos     :", state.pos)

# Keep this actual construction snapshot for the initial ParaView illustration.
scene_preview_state = state
scene_preview_system = jdem.System.create(state=state, collider_type="naive")
clump_id: [0 0 1]
pos_c   : [[2. 0.]
 [2. 0.]
 [6. 0.]]
pos_p   : [[-0.5  0. ]
 [ 0.5  0. ]
 [ 0.   0. ]]
pos     : [[1.5 0. ]
 [2.5 0. ]
 [6.  0. ]]
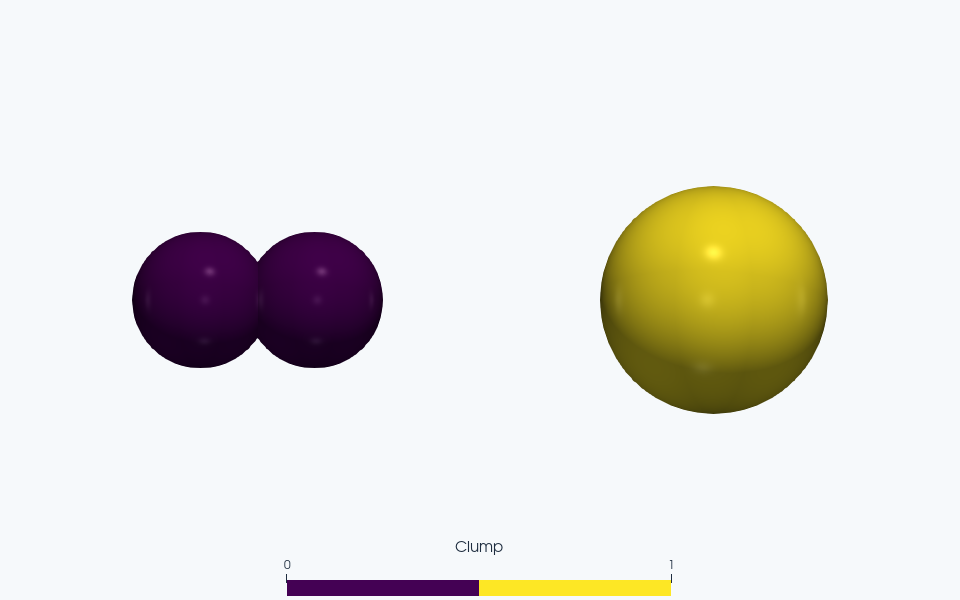
The two overlapping disks share one clump ID and move as a rigid body. The larger sphere has its own clump ID. ParaView renders their actual radii and body-frame offsets from this construction snapshot.
pos gives the true lab-frame position of each
sphere. In the dumbbell (clump 0) the two spheres sit at different
locations even though they share the same pos_c.
Using add_clump()#
A more convenient way to append a clump to an existing state is
add_clump(). It broadcasts shared fields
(velocity, mass, material, …) to all spheres automatically and assigns
a single clump_id to the whole group.
state_base = jdem.State.create(
    pos=jnp.array([[0.0, 0.0]]),
    rad=jnp.array([1.0]),
)
print("Before add_clump: N =", state_base.N, " clump_ids =", state_base.clump_id)

state_with_clump = jdem.State.add_clump(
    state_base,
    pos=jnp.array([[3.0, 0.0], [3.0, 0.0]]),  # COM for each sphere
    pos_p=jnp.array([[-0.4, 0.0], [0.4, 0.0]]),
    rad=jnp.array([0.5, 0.5]),
    vel=jnp.array([1.0, 0.0]),  # broadcast to both spheres
    mass=jnp.array(2.0),  # broadcast to both spheres
)
print(
    "After add_clump:  N =",
    state_with_clump.N,
    " clump_ids =",
    state_with_clump.clump_id,
)
print("Velocities:\n", state_with_clump.vel)
Before add_clump: N = 1  clump_ids = [0]
After add_clump:  N = 3  clump_ids = [0 1 1]
Velocities:
 [[0. 0.]
 [1. 0.]
 [1. 0.]]
Computing Clump Properties#
When you define a clump by placing overlapping spheres at arbitrary positions, you must compute the correct center of mass, total mass, and inertia tensor. This is not trivial because spheres may overlap. Summing individual volumes would over-count shared regions.
compute_clump_properties() computes the mass properties
of the union. In 2D it splits intersecting circles into exposed arcs and
integrates those arcs analytically. In 3D it combines analytical sphere
moments with numerical integration where needed: boundary quadrature for
sparse unions and direct volume quadrature for dense, heavily overlapping
unions. The dense path avoids undersampling tiny exposed boundary patches.
Separated and nested spheres have analytical properties in either
dimension, as do overlapping pairs of spheres in 3D. Analytical and sparse
boundary paths avoid spending samples in empty bounding-box space.
For clumps with at most 32 members, pairwise lens corrections are also
analytical when the overlap graph has no triangles. The shortcut is
conservative: more complicated overlap patterns use numerical integration.
The resulting density field determines:
total mass (accounting for overlap)
center of mass (
pos_c)principal moments of inertia (
inertia)principal-axes orientation (
q)body-frame offsets (
pos_p) relative to the new center of mass
These quantities are moments of the material union, not sums of independent overlapping spheres. With union \(\Omega\) and material density \(\rho(\mathbf{x})\),
and the three-dimensional inertia about the COM is
In 2D, area replaces volume and only \(I_{zz}=\int_\Omega\rho\lVert\mathbf{x}-\mathbf{c}\rVert^2dA\) is needed. Diagonalizing the 3D tensor defines principal moments and a body-frame orientation. If \(R\) maps that frame into the world, the member offsets become \(\mathbf{p}_i=R^T(\mathbf{x}_i-\mathbf{c})\); consequently \(\mathbf{c}+R\mathbf{p}_i=\mathbf{x}_i\), so changing the stored COM and principal frame does not move the physical spheres.
The shared mass and inertia belong to the whole rigid body. Although those values are broadcast to its member slots, summing all slots would count the same body repeatedly; select one representative per clump when computing body-level kinetic energy or total mass.
Where materials overlap, the utility uses the largest material density at each point, so neither volume nor overlapping mass is counted twice. It preserves the world-space sphere positions while updating the body frame. Principal frames have consistent signs and handedness; exactly repeated moments use a deterministic frame because their physical principal axes are not unique.
Important
compute_clump_properties() requires a
MaterialTable because the mass
computation depends on material density.
mat = jdem.Material.create("elastic", density=2.0, young=1e4, poisson=0.3)
mat_table = jdem.MaterialTable.from_materials([mat])

# Place two overlapping spheres at known positions
clump_state = jdem.State.create(
    pos=jnp.array([[0.0, 0.0], [0.8, 0.0]]),
    rad=jnp.array([0.5, 0.5]),
    clump_id=jnp.array([0, 0]),
    mat_table=mat_table,
)
print("Before compute_clump_properties:")
print("  pos_c:", clump_state.pos_c)
print("  pos_p:", clump_state.pos_p)
print("  mass :", clump_state.mass)

clump_state = jdem.utils.compute_clump_properties(clump_state, mat_table)
print("\nAfter compute_clump_properties:")
print("  pos_c:", clump_state.pos_c)
print("  pos_p:", clump_state.pos_p)
print("  mass :", clump_state.mass)
print("  inertia:", clump_state.inertia)
Before compute_clump_properties:
  pos_c: [[0.  0. ]
 [0.8 0. ]]
  pos_p: [[0. 0.]
 [0. 0.]]
  mass : [1.57079633 1.57079633]

After compute_clump_properties:
  pos_c: [[4.00000000e-01 1.48038716e-18]
 [4.00000000e-01 1.48038716e-18]]
  pos_p: [[-4.00000000e-01 -1.48038716e-18]
 [ 4.00000000e-01 -1.48038716e-18]]
  mass : [2.97809154 2.97809154]
  inertia: [[0.89195609]
 [0.89195609]]
Solid Member Spheres#
Every member disk or sphere is solid. The mass model uses their union: material occupies points inside at least one member, and overlaps count once. Space outside all supplied members stays empty, including enclosed cavities. To leave the center empty, supply a clump without a center sphere.
The geometric-asperity builder create_ga_state() distinguishes:
core_type="hollow"(default) generates only the solid asperities, without adding a center sphere. The name refers to the clump composition; each member sphere is still solid.core_type="solid": a central core contributes both material and contact geometry, in addition to the asperities.core_type="phantom": the core contributes mass, volume, and inertia, then is removed from the contact geometry. Its interior is still material.
compute_clump_properties() derives mass from the material density table.
The uniform-union helper used by create_ga_state() instead preserves the
requested total body mass and spreads it uniformly over the chosen union.
Both models preserve geometric voids and avoid double-counting overlaps.
Accuracy and Construction Cost#
The same call works in both dimensions. n_samples controls the total
numerical integration budget per 3D clump; it has no effect on analytical
2D arc integration or analytical 3D cases. The numerical budget has a floor
of 32 points per member; boundary quadrature also rounds up to an even
number of points per member. Increase it when a more accurate inertia
tensor is needed; there is no universal sample count that makes every
shape exact.
Any number of members may overlap. The 2D arc integrals remain analytical; general 3D integration evaluates coverage by all other members, including triple and higher-order overlaps. The pairwise analytical shortcut is used only when its overlap-graph check rules out triple intersections.
Adaptive selection keeps volume integration for dense cases where one
member alone guarantees useful bounding-box occupancy, and retains
boundary integration for sparse unions. A positive finite result does
not certify accuracy. For a 3D body requiring quadrature, compare
increasing budgets, for example 50_000, 200_000, and 800_000,
until volume, center of mass, and inertia meet the needed tolerances.
Compare inertia in world coordinates, R(q) @ diag(inertia) @ R(q).T:
quaternion signs and axes within an almost repeated eigenspace can change
even when the physical tensor agrees. Unresolved nonpositive properties
raise ValueError;
increasing samples or precision can resolve them.
sample_batch_size bounds the temporary sample arrays, while
clump_batch_size bounds the number of bodies processed together.
These settings control memory use without changing the integration rule.
Samples are generated as needed rather than stored as one large point
array, and their angular phases retain precision in float32.
The host wrapper groups clumps by their actual member counts. Small clumps therefore do not acquire padding to the largest clump in the state, and sparse IDs do not require a table indexed by their largest value. Single-sphere bodies keep their existing state properties. Compute these properties during construction, before running dynamics. The grouping step runs on the host, so call the wrapper outside jax.jit; its numerical kernels are compiled internally.
Collision Detection and Clumps#
All colliders automatically skip interactions between spheres
that belong to the same clump.
valid_interaction_mask() handles this:
is_bonded = jnp.any(bond_id_i == idx_j[..., None], axis=-1)
mask = (clump_i != clump_j) * (~is_bonded | interact_same_bond_id)
So spheres inside a clump never exert contact forces on each
other — they are a rigid assembly by construction. Colliders mask
bonded pairs (connected via bond_id) by default. Bonded pairs
interact when
interact_same_bond_id is True.
The colliders always mask same-clump pairs, regardless of that flag.
There are no special collider requirements: clumps work with all colliders.
clump_id vs bond_id#
These two identifiers serve different purposes:
clump_id— rigid body grouping. Spheres with the sameclump_idare physically fused: they share velocity, position, and orientation and never collide with each other.bond_id— connectivity masking. The colliders disable (mask out) pairwise interactions between spheres connected by a bond. Thebond_idarray holds the unique IDs of the spheres each sphere is connected to. Settinginteract_same_bond_idtoTruere-enables contact forces between bonded pairs (same-clump pairs stay masked either way).
In short: clump_id controls rigid-body aggregation and
collision masking, while bond_id controls localized connection masking.
See Deformable Particles for details on
deformable particles.
Force Aggregation#
The ForceManager handles clump-level force
aggregation in its apply() step. The pipeline is:
The collider writes per-sphere contact forces/torques into
force/torque.The force manager adds external forces (gravity, custom functions).
Particle-frame forces induce extra torque via the lever arm \(\tau_i = r_i \times F_i\), where \(r_i = R(q) \cdot pos\_p_i\).
The force manager sums forces and torques over each clump with jax.ops.segment_sum, using
clump_idas the segment key.It broadcasts the aggregated values back, so every sphere in the clump sees the same total force and torque.
This makes the clump accelerate and rotate as a single rigid body.
Running a Simulation with Clumps#
Drop a dumbbell onto a fixed spherical support and follow its elastic
rebound. Before contact its center of mass follows
y(t) = y(0) - g*t**2/2. During impact the two member contacts transfer
force and torque to one rigid body; the initial tilt makes the first
contact asymmetric, causing rotation. Their separation stays constant.
The spring law stores and releases contact energy without damping. All
lengths, masses, and times use consistent reduced units.
# Fixed floor sphere
pos_floor = jnp.array([[0.0, 0.0]])
rad_floor = jnp.array([1.0])

state_sim = jdem.State.create(pos=pos_floor, rad=rad_floor, mat_table=mat_table)
state_sim.fixed = jnp.array([True])

# Add a dumbbell clump above the floor
state_sim = jdem.State.add_clump(
    state_sim,
    pos=jnp.array([[0.0, 4.0], [0.0, 4.0]]),
    pos_p=0.4
    * jnp.array([[-jnp.cos(0.3), -jnp.sin(0.3)], [jnp.cos(0.3), jnp.sin(0.3)]]),
    rad=jnp.array([0.4, 0.4]),
)
print("N:", state_sim.N, " clump_ids:", state_sim.clump_id)

# Compute clump mass and inertia
state_sim = jdem.utils.compute_clump_properties(state_sim, mat_table)

system_sim = jdem.System.create(
    state_sim.shape,
    dt=1e-3,
    force_model_type="spring",
    collider_type="naive",
    mat_table=mat_table,
    force_manager_kw={"gravity": jnp.array([0.0, -9.81])},
)

# Save the initialized state and forty actual snapshots, spanning 1.6 time units.
state_sim, system_sim = jdem.System.initialize(state_sim, system_sim)
initial_com = np.asarray(state_sim.pos_c[1]).copy()
state_sim, system_sim, (scene_states, scene_systems) = jdem.System.trajectory_rollout(
    state_sim, system_sim, strides=jnp.asarray([0] + [40] * 40)
)
elapsed = float(scene_systems.time[1])
expected_com = initial_com + np.array([0.0, -0.5 * 9.81 * elapsed**2])
np.testing.assert_allclose(scene_states.pos_c[1, 1], expected_com, atol=2e-5)
np.testing.assert_allclose(
    scene_states.pos[:, 0],
    np.broadcast_to(np.asarray(pos_floor[0]), scene_states.pos[:, 0].shape),
    atol=1e-7,
)
np.testing.assert_allclose(
    scene_states.pos_c[:, 1], scene_states.pos_c[:, 2], atol=1e-7
)
member_vectors = np.asarray(scene_states.pos[:, 2] - scene_states.pos[:, 1])
member_separation = np.linalg.norm(member_vectors, axis=-1)
orientation_change = np.linalg.norm(member_vectors - member_vectors[0], axis=-1)
np.testing.assert_allclose(member_separation, 0.8, atol=2e-6)
assert float(scene_states.pos_c[:, 1, 1].min()) < 1.5
assert float(scene_states.vel[:, 1, 1].max()) > 1.0
assert np.isfinite(np.asarray(scene_states.ang_vel)).all()
assert float(jnp.abs(scene_states.ang_vel[:, 1]).max()) > 0.5
assert float(orientation_change.max()) > 0.1
system_sim.check_overflow()
print("Dumbbell COM:", state_sim.pos_c[1])
print("Floor position (unchanged):  ", state_sim.pos[0])
print("Peak upward rebound speed:", float(scene_states.vel[:, 1, 1].max()))
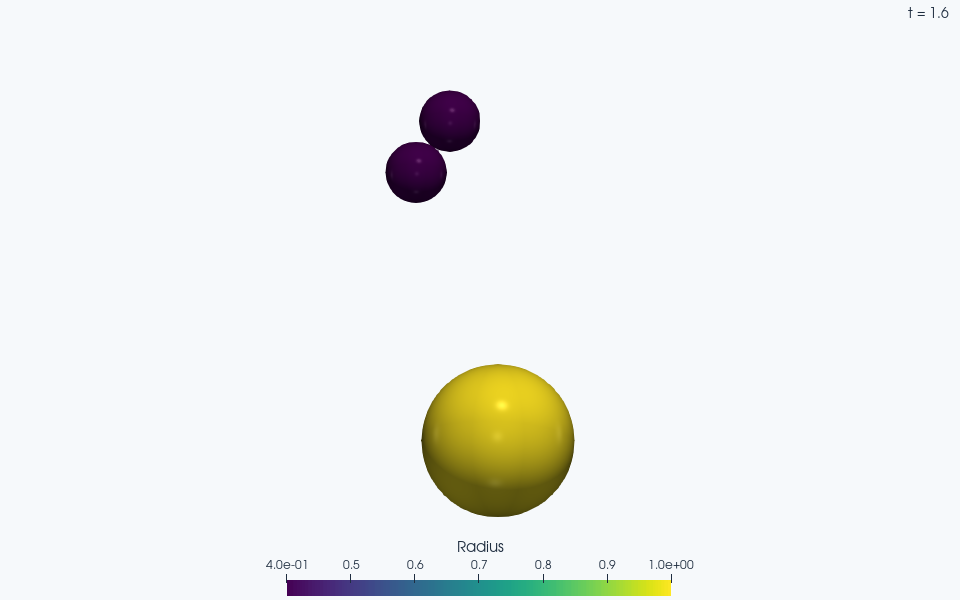
ParaView rendering of this run’s VTKWriter output.
N: 3  clump_ids: [0 1 1]
Dumbbell COM: [-0.84750918  3.836828  ]
Floor position (unchanged):   [0. 0.]
Peak upward rebound speed: 6.803632769489066
Integration and Clumps#
The linear and rotational integrators act on pos_c, vel, q,
and ang_vel. Because all spheres in a clump share these fields
(with the same values broadcast to every slot), the integrator moves
the entire clump as one rigid body without any special branching.
pos derives the actual sphere positions from pos_c and
pos_p on each access.
Reflective Domains and Clumps#
When a sphere inside a clump hits a reflective boundary, JaxDEM aggregates the velocity correction over the whole clump before applying it. This stops individual spheres from escaping while the correction pulls the rest of the body back, and preserves rigid-body integrity.
Common Pitfalls#
Forgetting to call
compute_clump_properties(). If you build a clump manually and skip this step, the mass, inertia, and center of mass will be those of a single sphere. The simulation will not be physically correct.Overlapping clumps with the same
clump_id. If two separate bodies accidentally share aclump_id, JaxDEM treats them as one rigid body. They do not interact through contact forces and they move together.Editing
clump_idafter construction.create()relabels input groups to contiguous IDs, so inputs such as[10, 10, 100, 100]become[0, 0, 1, 1]. Preserve that invariant when editing arrays directly: aggregation indexes an array withNsegments, so IDs outside[0, N)are invalid.Shared fields must be identical across a clump. If you manually set
vel,pos_c,q, etc., make sure all slots belonging to the same clump receive the same value.add_clump()handles this automatically by broadcasting.
Total running time of the script: (0 minutes 18.295 seconds)