Note
Go to the end to download the full example code.
Geometric-asperity deformable particles: step-by-step pipeline#
This example builds a packing of deformable particles (DPs) whose nodes
are the surface asperities of a geometric-asperity body. Each DP is a
soft body. A DeformableParticleModel
(or a plastic variant) holds it together and applies the standard DP
energies: area/volume (ec), element-measure (em), edges (el),
bending (eb), and surface tension (gamma).
Pipeline:
create_ga_state()withparticle_type='dp'builds a State where each node carriesmass / nvandunion_volume / nv, and shares abond_idwith every other node in its body.distribute_bodies()places each body’s bounding sphere at the target initial packing fraction and applies a uniform-random per-body rotation. The rotation rotates the DP nodes around their centroid.create_dp_container()builds the bonded-force container on the placed state. A per-body convex-hull test (ga_surface_mask()) detects surface and interior nodes. A body with a solid core gets an interior node connected with “fan”-style struts. A body without a center node has every node on the surface, with no extra edges.quasistatic_compress_to_packing_fraction()compresses to the target nominal packing fraction while the DP bonds keep each body self-consistent.Build a Verlet system (with the container as
bonded_force_model) and run a few time steps.
The nominal packing fraction uses the stored reference sphere-union volume shares. It is not the instantaneous area/volume enclosed by a deformed DP mesh, including when the body has no center node. A small dilute 2D configuration keeps construction and relaxation quick; the same pipeline accepts 3D meshes.
Imports
import jax

import numpy as np

jax.config.update("jax_enable_x64", True)  # type: ignore[no-untyped-call]

import jaxdem as jdem
from jaxdem.utils.particle_creation import (
    create_ga_state,
    create_dp_container,
    distribute_bodies,
)
from jaxdem.utils.packing_utils import (
    compute_packing_fraction,
    CompressionReason,
    quasistatic_compress_to_packing_fraction,
)
Parameters#
Three deformable particles in 2D, six surface asperities each. The default
core_type='hollow' adds no center node; every member is still solid.
Set core_type='solid' to add a central node connected to every surface
node via interior_edges='fan'.
N = 3
nv = 6
dim = 2
particle_radius = 0.5
asperity_radius = 0.1
initial_phi_bb = 0.15
target_phi = 0.05  # nominal sphere-union fraction, not enclosed mesh area
seed = 0
1) Build the DP state#
DP nodes get equal shares of mass and union volume. bond_id groups
them by body. create_ga_state applies no rigid-body frame. Each
node’s pos_c is its world-frame position.
For body mass \(M_I\), reference union volume \(V_{I,0}\), and
\(n_I\) nodes, this construction assigns \(M_I/n_I\) and
\(V_{I,0}/n_I\) to each node. Summing those shares recovers the body
totals. Unlike rigid-clump members, DP nodes have separate translational
degrees of freedom: their relative positions are controlled by bonds,
rather than by a shared quaternion and fixed body-frame offsets.
state = create_ga_state(
    N=N,
    nv=nv,
    dim=dim,
    particle_radius=particle_radius,
    asperity_radius=asperity_radius,
    particle_type="dp",
    core_type="hollow",
    n_samples=2_048,  # 2D union properties are analytical; no samples are used
    seed=seed,
    mesh_type="fibonacci",
)
print(f"DP state: N={state.N} nodes, {N} bodies")
DP state: N=18 nodes, 3 bodies
Place + orient bodies
state, box_size = distribute_bodies(
    state,
    phi=initial_phi_bb,
    domain_type="periodic",
    seed=seed,
    randomize_orientation=True,
)
print(f"placed at bounding-sphere phi={initial_phi_bb}: box = {np.asarray(box_size)}")
placed at bounding-sphere phi=0.15: box = [3.9633273 3.9633273]
3) Build the DP container#
Build the container from the placed state so that its
initial_edge_lengths / initial_bendings / etc. reflect the
actual rest configuration. A per-body convex-hull test detects
is_surface. Here every node is on the hull.
interior_edges='fan' connects any interior (core) node to every
surface node in its body. It is a no-op here because there are no
interior nodes, but it matters for core_type='solid'.
The reference geometry is part of the constitutive model. Edge and element penalties compare current lengths/measures with values recorded here, while the content term compares enclosed area/volume with its reference value. A rigid placement or rotation leaves those quantities unchanged. Constructing a new container after deformation would instead declare that deformed shape to be the new reference, removing its elastic strain. Keep this container throughout compression and dynamics.
container = create_dp_container(
    state,
    em=1.0,
    ec=1.0,
    eb=0.1,  # bending is stiff for small triangles; keep this modest
    el=0.3,
    gamma=None,  # no surface tension in this example
    interior_edges="fan",
)
print(f"container: {type(container).__name__}")
print(
    f"   elements: {container.elements.shape if container.elements is not None else None}"
)
print(f"   edges:    {container.edges.shape if container.edges is not None else None}")
print(
    f"   adjacency:{container.element_adjacency.shape if container.element_adjacency is not None else None}"
)
container: DeformableParticleModel
   elements: (18, 2)
   edges:    (18, 2)
   adjacency:(18, 2)
4) Compress with FIRE, DP bonds active#
Compression calls scale_to_packing_fraction, which translates every
body’s centroid uniformly (internal geometry preserved), and then FIRE
relaxes. Because the System holds the DP container, bonded forces keep
each body coherent. Contact forces from other bodies can still deform
it locally.
More explicitly, write a node as \(\mathbf{x}_{Ii}=\mathbf{c}_I+\mathbf{u}_{Ii}\) relative to its body’s centroid. A box rescale about anchor \(\mathbf{a}\) applies
The affine event translates each body without straining its internal mesh. Its subsequent relaxation can change the enclosed content. The nominal \(\phi=\sum_I V_{I,0}/V_{\mathrm{box}}\) still uses reference shares, so an instantaneous enclosed-content fraction would need to be measured separately from the current mesh geometry.
mats = [jdem.Material.create("elastic", young=1.0, poisson=0.5, density=1.0)]
mat_table = jdem.MaterialTable.from_materials(
    mats, matcher=jdem.MaterialMatchmaker.create("harmonic")
)
fire_system = jdem.System.create(
    state_shape=state.shape,
    dt=1e-2,
    minimizer=jdem.minimizers.fire,
    minimizer_kw={"dt": 1e-2},
    domain_type="periodic",
    force_model_type="spring",
    collider_type="naive",
    mat_table=mat_table,
    domain_kw={"box_size": box_size},
    bonded_force_model=container,
)

phi0 = float(compute_packing_fraction(state, fire_system))
print(f"before compression: nominal phi = {phi0:.4f}")

compression = quasistatic_compress_to_packing_fraction(
    state,
    fire_system,
    target_phi=target_phi,
    step=0.01,
    force_tol=1e-8,
    max_n_min_steps_per_outer=2_000,
    max_n_outer_steps=12,
)
if compression.reason != CompressionReason.TARGET_REACHED:
    raise RuntimeError(
        f"Compression stopped: {compression.reason.name}; "
        f"minimizer: {compression.minimizer_reason.name}"
    )
state, fire_system, final_phi, final_pe = compression
np.testing.assert_allclose(final_phi, target_phi, atol=1e-9)
print(
    f"after compression:  nominal phi = {float(final_phi):.4f}  PE/node = {float(final_pe):.3e}"
)
before compression: nominal phi = 0.0360
after compression:  nominal phi = 0.0500  PE/node = 2.432e-32
5) Short Verlet rollout (dynamics)#
dataclasses.replace swaps the FIRE setup for plain Verlet
and keeps everything else. This includes the post-compression box size,
the material table, the collider, and the DP bonded-force
container, so no manual rebuild is needed. Passing "" disables
the rotation integrator: DP nodes carry no rigid-body orientation.
import jax.numpy as jnp

import dataclasses

from jaxdem.integrators import LinearIntegrator, RotationIntegrator

sim_system = dataclasses.replace(
    fire_system,
    linear_integrator=LinearIntegrator.create("verlet"),
    rotation_integrator=RotationIntegrator.create(
        ""
    ),  # disable rotation: DPs have no rigid-body orientation
    dt=jnp.asarray(1e-3, dtype=float),
)

state, sim_system = jdem.System.initialize(state, sim_system)
state, sim_system = sim_system.step(state, sim_system, n=10)
assert np.all(np.isfinite(state.pos))
print("10 Verlet steps completed")
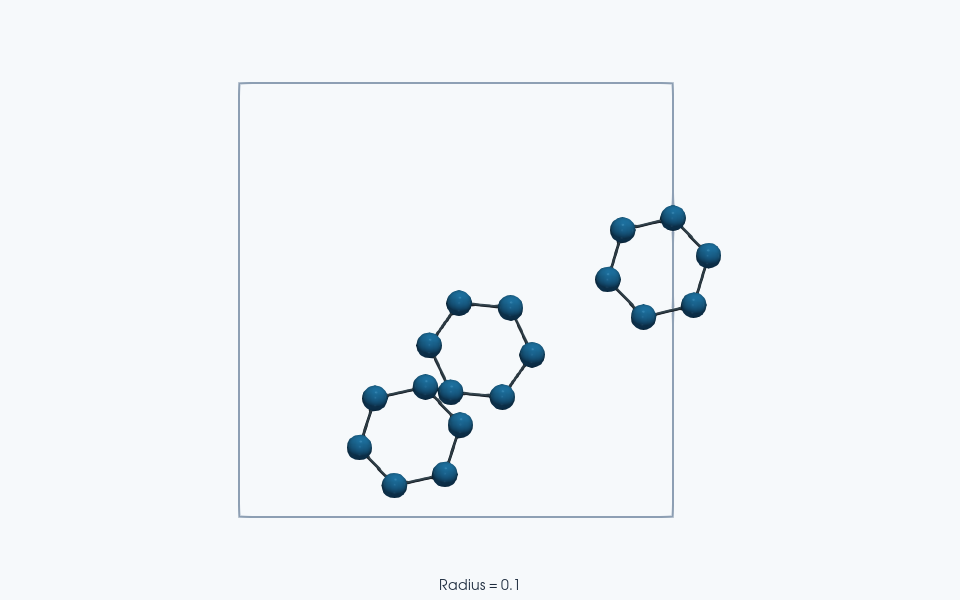
ParaView rendering of this run’s VTKWriter output.
10 Verlet steps completed
Total running time of the script: (0 minutes 15.845 seconds)