Note
Go to the end to download the full example code.
SASA of a rigid clump via a spherical tracer#
SASA (“solvent-accessible surface area”) is the surface that the
center of a spherical probe traces as it rolls over a body.
Equivalently, it is the boundary of the Minkowski sum of the body with
a ball of the probe’s radius. This example builds a single rigid GA
clump, probes it with a smooth sphere of radius r_tracer, and
estimates the SASA from the per-direction center-to-center
separations that
compute_surface_properties()
reports.
For each approach direction d_i on S^2, sphere-ray intersections
locate the first contact from outside at target_overlap. This also
works when the ray crosses several disconnected contact intervals.
The center-to-center separation separation[i] is the distance from
the central clump’s COM to the SASA surface along d_i. A missed ray
or a contact without a resolved normal force gives NaN.
The radial surface reconstruction below requires a surface visible from the
body’s center: hidden cavities and overhangs cannot be recovered from one
outermost contact per direction. The solid-core shape used here meets that
restriction. SciPy is needed for the spherical triangulation.
Numerics#
target_overlapis how much interpenetration the “just-touching” configuration tolerates. Keep it much smaller than any physical length scale in the problem, so the tracer is effectively at zero contact (we define SASA at contact, not inside the body).separation_toleranceis retained for API compatibility and validation. It must be positive and smaller thantarget_overlap; the direct contact roots have no iteration tolerance.Enable x64 before any JAX operation to resolve the small overlap used here (
1e-10) at the body’s length scale. Float32 roundoff can erase that overlap and leave the measured force unresolved.
Enable x64 before any other JAX work.
import jax

jax.config.update("jax_enable_x64", True)  # type: ignore[no-untyped-call]

import numpy as np
import matplotlib.pyplot as plt

from jaxdem.utils.particle_creation import create_ga_state, create_sphere_state
from jaxdem.utils.surface_properties import compute_surface_properties
Central rigid clump + tracer sphere#
The central body is an eight-asperity rigid clump with a solid core. The
tracer is a single smooth sphere built with create_sphere_state(),
which needs no asperity mesh or union-boundary property integration.
A deterministic Fibonacci mesh and a small direction count keep this
demonstration quick. Increase n_points to check surface resolution.
central = create_ga_state(
    N=1,
    nv=8,
    dim=3,
    particle_radius=0.5,
    asperity_radius=0.1,
    particle_type="clump",
    core_type="solid",  # fill the central void so each approach ray meets the body
    n_samples=2_048,  # 3D boundary-quadrature budget when an analytical case is unavailable
    seed=0,
    mesh_type="fibonacci",
)

tracer_radius = 0.05
tracer = create_sphere_state(radii=tracer_radius, dim=3)
Probe the surface#
Keep target_overlap small and the compatibility tolerance below it.
n_orientations = n_rolls = 1 because a smooth sphere has no
orientation degree of freedom.
target_overlap = 1e-10
separation_tolerance = 1e-12
n_points = 192

result = compute_surface_properties(
    central,
    tracer,
    target_overlap=target_overlap,
    separation_tolerance=separation_tolerance,
    n_points=n_points,
    n_orientations=1,
    n_rolls=1,
)

separation = np.asarray(result["separation"]).reshape(n_points)
assert np.all(np.isfinite(separation))
print(
    f"separation: min={separation.min():.4f}  max={separation.max():.4f}  mean={separation.mean():.4f}"
)
separation: min=0.4498 max=0.5495 mean=0.4620
SASA from the per-direction separations#
Triangulate the approach directions on S^2. Their 3D convex hull
is a Delaunay triangulation of points on the sphere. Lift each
triangle vertex to the SASA surface with separation[i] *
direction[i] and sum the Euclidean triangle areas. The result is
the surface area of the polyhedron with the sampled tracer-center
positions as vertices. For a radially representable surface, refinement
reduces the discretization error; a single coarse estimate is not a
converged surface-area measurement.
If the material body is a union of balls \(K=\bigcup_j B(\mathbf{c}_j,a_j)\), the spherical tracer’s accessible center positions have boundary \(\partial(K\oplus B(0,r_{\mathrm{tracer}}))\). Dilation distributes over this union, so each member’s contact radius becomes \(a_j+r_{\mathrm{tracer}}\). The outward ray intersections find the outer envelope of those inflated members.
Denote a sampled unit direction by \(\mathbf{d}_i\) and its measured separation by \(\rho_i\). The reconstructed vertices are \(\mathbf{x}_i=\rho_i\mathbf{d}_i\), and each triangle contributes
Triangulating the directions first preserves their angular neighborhood ordering; taking the convex hull of the reconstructed surface itself would fill concave parts of that surface. For a smooth radial surface, the corresponding continuous area element is
This explains why equal solid-angle samples do not have equal surface area on a rough body. For a smooth sphere, \(\rho=R+r_{\mathrm{tracer}}\) is constant and integration recovers \(4\pi\rho^2\), the reference checked below. Resolving sharp changes in \(\rho\) requires more directions, even when the contact-root calculation is already accurate.
from scipy.spatial import ConvexHull

directions = np.asarray(result["approach_directions"])  # (N, 3) on S^2
triangles = ConvexHull(directions).simplices  # (F, 3) vertex idx


def radial_surface_area(radii):
    surface_points = radii[:, None] * directions
    tri = surface_points[triangles]
    e1 = tri[:, 1] - tri[:, 0]
    e2 = tri[:, 2] - tri[:, 0]
    return 0.5 * float(np.sum(np.linalg.norm(np.cross(e1, e2), axis=-1)))


sasa = radial_surface_area(separation)

print(f"estimated SASA = {sasa:.4f}")
estimated SASA = 2.7707
A smooth-sphere reference gives a known answer with the same probe radius.
Its contact separation is R + r_tracer and its SASA is
4*pi*(R + r_tracer)**2. The polyhedral estimate slightly underestimates
the spherical area at this deliberately coarse angular resolution.
sphere_radius = 0.5
sphere = create_sphere_state(radii=sphere_radius, dim=3)
sphere_result = compute_surface_properties(
    sphere,
    tracer,
    target_overlap=target_overlap,
    separation_tolerance=separation_tolerance,
    n_points=n_points,
    n_orientations=1,
    n_rolls=1,
)
sphere_separation = np.asarray(sphere_result["separation"]).reshape(n_points)
np.testing.assert_allclose(sphere_separation, sphere_radius + tracer_radius, atol=2e-9)
sphere_area = radial_surface_area(sphere_separation)
exact_area = 4 * np.pi * (sphere_radius + tracer_radius) ** 2
relative_error = abs(sphere_area / exact_area - 1)
assert relative_error < 0.04
print(f"smooth-sphere area: estimated={sphere_area:.4f}, exact={exact_area:.4f}")
print(f"angular discretization relative error = {relative_error:.2%}")
smooth-sphere area: estimated=3.7395, exact=3.8013
angular discretization relative error = 1.63%
Inspect roughness and the angular discretization error#
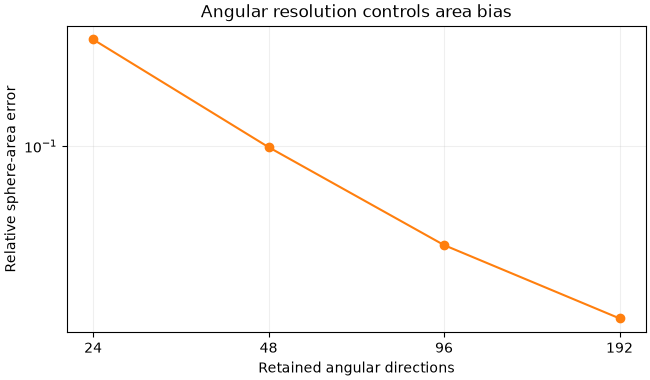
Reuse subsets of the measured sphere directions and compute their convex polyhedron’s area. This reference sphere is convex, so the hull gives the same triangular area construction above. No additional contact probes or geometry optimization are required.
angular_counts = np.array([24, 48, 96, n_points])
reference_errors = []
for count in angular_counts:
    indices = np.arange(0, n_points, n_points // count)
    reference_vertices = sphere_separation[indices, None] * directions[indices]
    reference_errors.append(abs(ConvexHull(reference_vertices).area / exact_area - 1.0))

fig, ax = plt.subplots(figsize=(6.5, 3.8), layout="constrained")
ax.loglog(angular_counts, reference_errors, "o-", color="tab:orange")
ax.set(
    xticks=angular_counts,
    xticklabels=[str(n) for n in angular_counts],
    xlabel="Retained angular directions",
    ylabel="Relative sphere-area error",
    title="Angular resolution controls area bias",
)
ax.minorticks_off()
ax.grid(alpha=0.2)
plt.show()
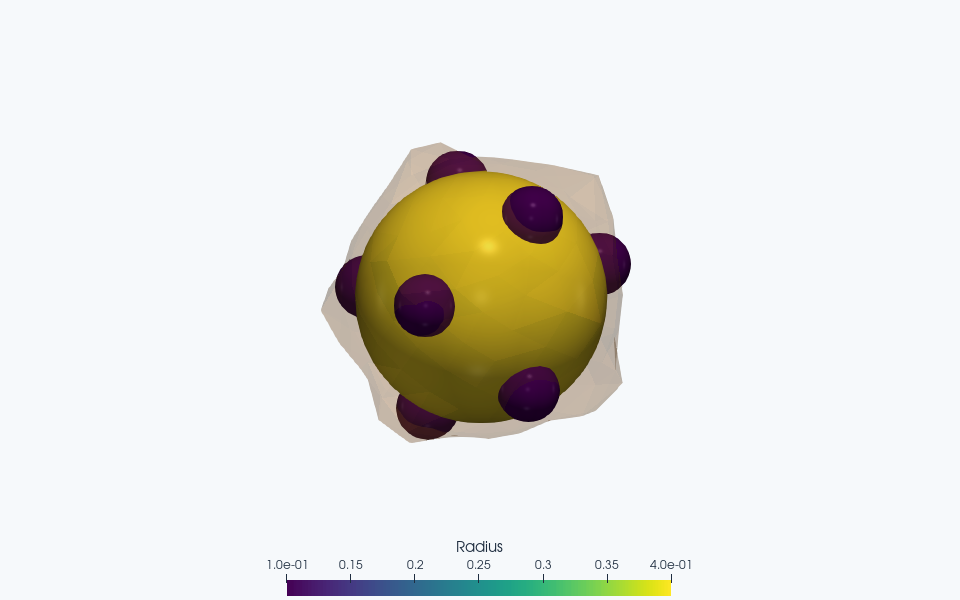
ParaView rendering of this run’s VTKWriter output.
The smooth-sphere error measures angular triangulation bias even though its contact distances are already accurate. It does not bound the rough clump’s SASA error: sharp surface features can demand finer directional sampling. The directional samples have equal solid-angle weights rather than equal surface-area weights.
Total running time of the script: (0 minutes 11.037 seconds)