Note
Go to the end to download the full example code.
Rigid geometric-asperity clumps: step-by-step pipeline#
This example shows the full pipeline to build a relaxed, dilute
packing of rigid geometric-asperity (GA) clumps at a chosen true-body
packing fraction. It uses the primitives in
jaxdem.utils.particle_creation and jaxdem.utils.packing_utils.
The flow is:
create_ga_state()— build a state ofNidentical clumps. Each clump hasnvsurface asperities on a sphere or ellipsoid surface, plus an optional solid core. The deterministic Fibonacci construction used here avoids iterative mesh optimization. Boundary integration of the sphere union gives the per-clump volume, COM, principal inertia, and principal-axis quaternion. The function stores these on the returnedState.distribute_bodies()— build one bounding sphere per clump (radius =max(|node - centroid| + rad)) and place the spheres uniformly in a box sized for an initial bounding-sphere packing fraction. It then FIRE-minimizes the analogue sphere system, moves each clump’s centroid to the minimized location, and gives each clump a random orientation.quasistatic_compress_to_packing_fraction()— shrink the box in steps toward the target true-body packing fraction, and minimize after each step.
At the end, a short time-integration with the Verlet + spiral integrators confirms the resulting state and system are ready to simulate. The small system is intentionally below jamming: relaxation removes forces, but does not establish a mechanically rigid packing.
Imports
import jax

import numpy as np

jax.config.update("jax_enable_x64", True)  # type: ignore[no-untyped-call]

import jaxdem as jdem
from jaxdem.utils.packing_utils import (
    compute_packing_fraction,
    CompressionReason,
    quasistatic_compress_to_packing_fraction,
)
from jaxdem.utils.particle_creation import create_ga_state, distribute_bodies
Parameters#
Three identical clumps in 3D, each with six surface asperities on a sphere of radius 0.5 and a solid core, so the rigid-body property calculation captures the enclosed volume.
N = 3
nv = 6
dim = 3
particle_radius = 0.5
asperity_radius = 0.1
Two distinct packing fractions: the bounding-sphere fraction for the
initial random placement, and the true-body fraction we compress to. The
one-call build_ga_system() exposes the
former as its initial_phi_bb parameter (default 0.3).
These two fractions refer to different geometries. If body \(I\) has member offsets \(\mathbf{p}_{Ii}\) about its center and member radii \(a_{Ii}\), its conservative bounding radius is
Here \(V_I\) is the union volume of the solid members, including the chosen core. Usually it is smaller than the bounding sphere. Keeping the bounding spheres apart gives a safe loose placement; matching their fraction alone would not produce the requested material fraction.
initial_phi_bb = 0.15  # bounding-sphere packing fraction at placement
target_phi = 0.12  # union-volume fraction; distinct from bounding-sphere phi
seed = 0
1) Build the template clumps#
create_ga_state does most of the work: asperity
positions, union-volume / COM / inertia, and an aligned
principal-axis quaternion. For core_type='solid' it adds a central
sphere of radius core_radius = particle_radius - asperity_radius
and keeps it in the final state. For 'phantom' the core only feeds
the property computation, and the function removes it from the state.
With the default core_type="hollow", it adds no center sphere.
state = create_ga_state(
    N=N,
    nv=nv,
    dim=dim,
    particle_radius=particle_radius,
    asperity_radius=asperity_radius,
    particle_type="clump",
    core_type="solid",
    n_samples=2_048,  # modest surface quadrature budget for this small example
    seed=seed,
    mesh_type="fibonacci",
)
print(
    f"clumps built: total nodes = {state.N}, clump_ids cover {int(state.clump_id.max()) + 1} bodies"
)
clumps built: total nodes = 21, clump_ids cover 3 bodies
2) Place each clump’s bounding sphere at the initial packing fraction#
distribute_bodies places each body’s bounding sphere (center = COM,
radius = furthest sphere outer edge) uniformly at random in a periodic
box. It sizes the box so that total bounding-sphere volume / box volume
= initial_phi_bb. It FIRE-minimizes the analogue sphere system to
remove overlaps, and gives each clump a random uniform rotation.
state, box_size = distribute_bodies(
    state,
    phi=initial_phi_bb,
    domain_type="periodic",
    seed=seed,
    randomize_orientation=True,
)
print(f"placed at bounding-sphere phi={initial_phi_bb}: box = {np.asarray(box_size)}")
placed at bounding-sphere phi=0.15: box = [2.1904817 2.1904817 2.1904817]
3) Build a FIRE-based system for compression#
The compression routine expects a system with a FIRE minimizer. We use the naive collider for simplicity — the neighbor list would also work.
mats = [jdem.Material.create("elastic", young=1.0, poisson=0.5, density=1.0)]
mat_table = jdem.MaterialTable.from_materials(
    mats, matcher=jdem.MaterialMatchmaker.create("harmonic")
)
fire_system = jdem.System.create(
    state_shape=state.shape,
    dt=1e-2,
    minimizer=jdem.minimizers.fire,
    minimizer_kw={"dt": 1e-2},
    domain_type="periodic",
    force_model_type="spring",
    collider_type="naive",
    mat_table=mat_table,
    domain_kw={"box_size": box_size},
)

phi_bb = float(compute_packing_fraction(state, fire_system))
print(
    f"before compression: true-body phi = {phi_bb:.4f} (bounding-sphere target was {initial_phi_bb})"
)
before compression: true-body phi = 0.0804 (bounding-sphere target was 0.15)
4) Quasistatic compression to the target true-body phi#
The compression steps by at most step in phi per outer iteration.
It calls scale_to_packing_fraction then minimize each time, and
truncates the final step so it hits the target phi exactly.
At each rescale, \(s=(\phi/\phi_{\mathrm{next}})^{1/d}\) multiplies
the box lengths and body-center separations, while offsets and radii keep
each rigid body’s shape unchanged. Relaxation then adjusts its translation
and rotation in response to the new contacts. An energy minimum can have
positive contact energy; convergence is determined by force and torque
residuals, not by requiring all overlaps to vanish.
compression = quasistatic_compress_to_packing_fraction(
    state,
    fire_system,
    target_phi=target_phi,
    step=0.02,
    force_tol=1e-8,
    max_n_min_steps_per_outer=2_000,
    max_n_outer_steps=12,
)
if compression.reason != CompressionReason.TARGET_REACHED:
    raise RuntimeError(
        f"Compression stopped: {compression.reason.name}; "
        f"minimizer: {compression.minimizer_reason.name}"
    )
state, fire_system, final_phi, final_pe = compression
np.testing.assert_allclose(final_phi, target_phi, atol=1e-9)
print(
    f"after compression:  phi = {float(final_phi):.4f}  PE/node = {float(final_pe):.3e}"
)
print(f"box = {np.asarray(fire_system.domain.box_size)}")
after compression:  phi = 0.1200  PE/node = 0.000e+00
box = [1.91708288 1.91708288 1.91708288]
5) Switch to Verlet integrators for dynamics and run a short rollout#
dataclasses.replace returns a copy of the FIRE system with
new integrators and dt. Every other component stays, including
the domain with its post-compression box size, the material
table, and the collider, so no manual rebuild is needed. Here we use
verlet linear + verletspiral rotation for a standard Newtonian
rollout.
import jax.numpy as jnp

import dataclasses

from jaxdem.integrators import LinearIntegrator, RotationIntegrator

sim_system = dataclasses.replace(
    fire_system,
    linear_integrator=LinearIntegrator.create("verlet"),
    rotation_integrator=RotationIntegrator.create("verletspiral"),
    dt=jnp.asarray(1e-3, dtype=float),
)

state, sim_system = jdem.System.initialize(state, sim_system)
state, sim_system = sim_system.step(state, sim_system, n=10)
assert np.all(np.isfinite(state.pos))
_, _, pe = sim_system.collider.compute_potential_energy(state, sim_system)
print(f"10 Verlet steps completed; final PE ~ {float(pe):.3e}")
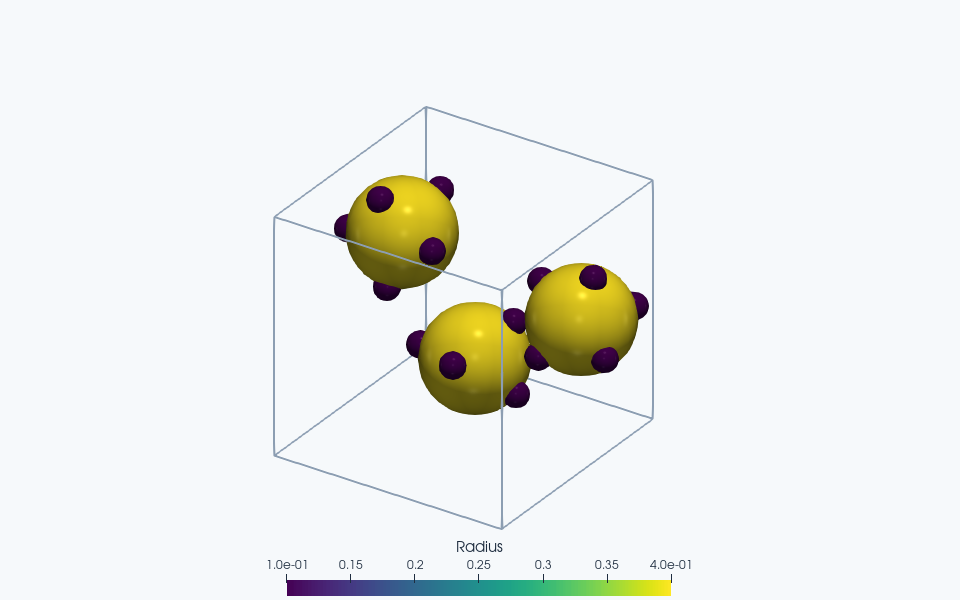
ParaView rendering of this run’s VTKWriter output.
Explore this scene in 3D
10 Verlet steps completed; final PE ~ 0.000e+00
Total running time of the script: (0 minutes 15.141 seconds)