Note
Go to the end to download the full example code.
Catch-all builder: polydisperse GA/DP packings in one call#
build_ga_system() bundles the full
pipeline (create_ga_state → distribute_bodies → container build
for DPs → FIRE compression → final System.create with the user’s
chosen integrator/collider/material) into a single call. It handles
polydispersity across the bodies — per-body particle_radius,
vertex_counts, asperity_radius, aspect_ratio, and Thomson
minimization steps — by grouping bodies with identical specs so
construction work can be shared within each group.
This example runs two small 2D configurations: bidisperse rigid clumps
with a nontrivial aspect ratio, followed by deformable particles. The DP
variant returns its bonded-force container alongside (state, system).
For 3D construction see the clump and sphere construction tutorials; using
2D here keeps the first run short, including JAX compilation.
These deliberately small, dilute configurations demonstrate the builder API quickly. Deterministic Fibonacci meshes avoid iterative mesh optimization. Increase the body count, mesh resolution, and relaxation budget for a physical study, and check convergence again. For DPs, the reported packing fraction uses stored reference sphere-union volumes, not the instantaneous enclosed mesh volumes.
The builder separates three levels of description. A body has a nominal
size and aspect ratio; its contact geometry consists of asperity spheres;
the returned State stores those constituent spheres or DP nodes. With
\(n_I\) nodes on body \(I\), the node count is
\(N_{\mathrm{nodes}}=\sum_I n_I\), which differs from the number of
independent rigid bodies. vertex_counts changes this geometric
resolution, whereas particle_radii changes body size. aspect_ratio
sets one relative scale per coordinate and can vary independently by body.
For rigid clumps, member forces and their lever-arm moments drive one translation and rotation per body. For DPs, the nodes move independently and the bonded container supplies the internal elastic forces. This is why the DP call returns a third object and disables the rigid rotation module. The same builder also accepts 3D geometry: use three-component aspect ratios and a suitable surface mesh, as in the construction pipelines. Those variants need not all execute to explain the common interface.
The reported fraction is \(\phi=\sum_I V_I/V_{\mathrm{box}}\). A rigid body’s \(V_I\) is its selected material-union volume, with overlapping members counted once. For a DP it is the stored reference union volume; it is distinct from the current area or volume enclosed by its mesh.
Imports
import jax

import numpy as np

jax.config.update("jax_enable_x64", True)  # type: ignore[no-untyped-call]

from jaxdem.utils.packing_utils import compute_packing_fraction
from jaxdem.utils.particle_creation import build_ga_system


def summarize(label, state, system, target_phi, container=None):
    phi = float(compute_packing_fraction(state, system))
    box = np.asarray(system.domain.box_size)
    extra = "" if container is None else f"  [{type(container).__name__}]"
    np.testing.assert_allclose(phi, target_phi, atol=1e-9)
    state, system = system.evaluate_forces(state, system)
    max_force = float(np.max(np.linalg.norm(np.asarray(state.force), axis=-1)))
    assert np.isfinite(max_force) and max_force < 1e-6
    system.check_overflow()
    print(f"[{label}]  N={state.N}  phi={phi:.4f}  box={box}{extra}")
    print(f"  maximum residual force = {max_force:.2e}")
1) Bidisperse rigid clumps with aspect ratio#
One large and one small body have the same four-asperity topology. Per-body radii and aspect ratios illustrate polydispersity without a large packing. An aspect ratio has one entry per spatial dimension; supply one such vector per body to vary the shape independently of its size.
state, system = build_ga_system(
    particle_radii=[0.5, 0.3],
    vertex_counts=[4, 4],
    asperity_radius=0.1,
    aspect_ratio=[[1.0, 1.4], [1.0, 1.2]],
    phi=0.12,
    dim=2,
    particle_type="clump",
    core_type="solid",
    domain_type="periodic",
    mesh_type="fibonacci",
    initial_phi_bb=0.15,
    compression_step=0.025,
    compression_force_tol=1e-8,
    max_n_min_steps_per_outer=500,
    dt=1e-3,
    linear_integrator_type="verlet",
    rotation_integrator_type="verletspiral",
    collider_type="naive",
    seed=0,
)
summarize("2D bidisperse, anisotropic clumps", state, system, 0.12)
[2D bidisperse, anisotropic clumps]  N=10  phi=0.1200  box=[2.4333547 2.4333547]
  maximum residual force = 0.00e+00
2) Deformable particles#
The DP path returns a third value (the container), which the builder
already wires into system via bonded_force_model. The example
supplies the energies em, ec, eb, el and leaves gamma (surface
tension) off for brevity. Pass dp_plasticity_type + dp_tau_s to get
an edge / perimeter / bending plastic variant instead.
state, system, container = build_ga_system(
    particle_radii=[0.5] * 2,
    vertex_counts=[4] * 2,
    asperity_radius=0.1,
    phi=0.02,
    dim=2,
    particle_type="dp",
    core_type="hollow",
    domain_type="periodic",
    mesh_type="fibonacci",
    initial_phi_bb=0.10,
    compression_step=0.01,
    compression_force_tol=1e-8,
    max_n_min_steps_per_outer=500,
    dt=1e-3,
    linear_integrator_type="verlet",
    rotation_integrator_type=None,  # DPs have no rigid-body orientation
    collider_type="naive",
    dp_em=1.0,
    dp_ec=1.0,
    dp_eb=0.1,  # modest bending stiffness for the small boundary mesh
    dp_el=0.3,
    dp_gamma=None,
    seed=2,
)
summarize("2D DPs", state, system, 0.02, container)
[2D DPs]  N=8  phi=0.0200  box=[3.5449077 3.5449077]  [DeformableParticleModel]
  maximum residual force = 3.68e-16
Short rollout on the DP system to confirm everything composes#
state, system = system.initialize(state, system)
state, system = system.step(state, system, n=10)
assert np.all(np.isfinite(state.pos))
print("10 Verlet steps on the DP system completed cleanly.")
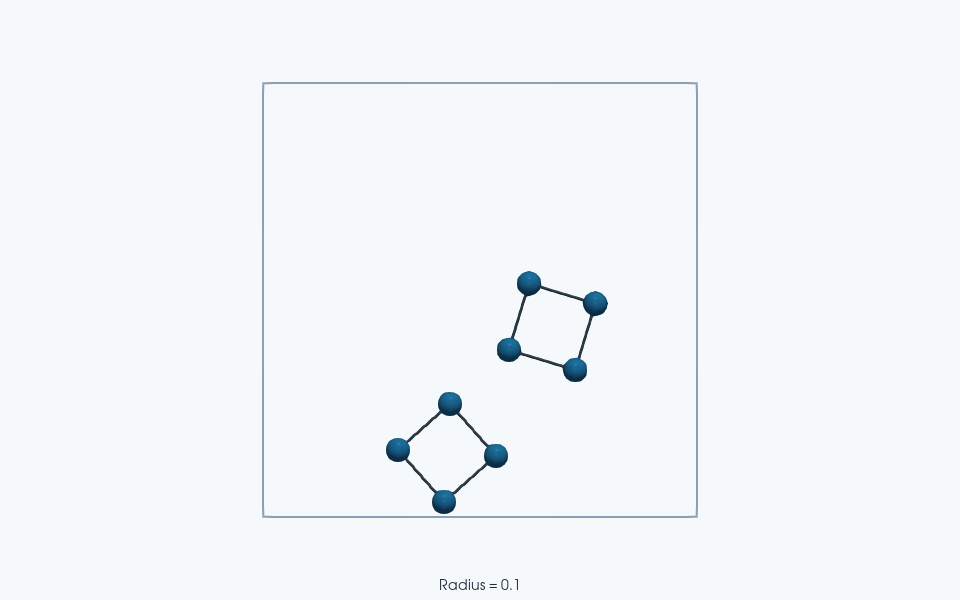
ParaView rendering of this run’s VTKWriter output.
10 Verlet steps on the DP system completed cleanly.
Total running time of the script: (0 minutes 20.405 seconds)